Descriptor State-Space
R2026bModel continuous linear system as system of implicit state-space equations
Descriptor State-Space block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Simulink /
Continuous
Description
The Descriptor State-Space block models a continuous linear system as a system of differential equations expressed in the implicit form:
where:
x is the state vector.
u is the input vector.
y is the output vector.
The matrices E, A, B, C, and D contain the coefficients of the terms in the system equations.
You can use the Descriptor State-Space block to model both time invariant and time variant linear implicit systems.
To model time-invariant systems, specify the E, A, B, C, and D parameters as constant matrices.
To model time-variant systems, tune the A, B, C, D, and E parameters during simulation. (since R2026a)
Specify System Matrices
To model a system, specify the system matrices using the E, A, B, C, and D parameters. You can specify either sparse or full matrices. By default, MATLAB® creates full matrices.
For more information, see Constructing Sparse Matrices.
The number of states, inputs, and outputs in the system determine the dimensions of the system matrices. For a system with n states, m inputs, and r outputs, the dimensions are:
E — n-by-n
A — n-by-n
B — n-by-m
C — r-by-n
D — r-by-m
Examples
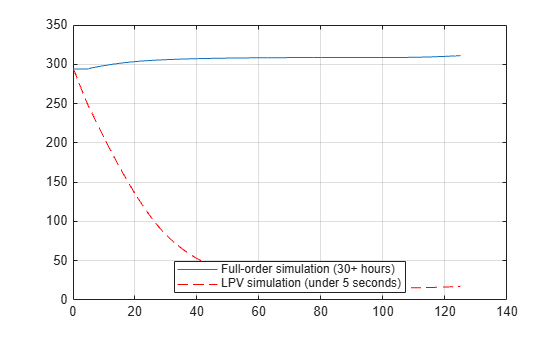
Create Low-Order LPV Model of CPU and Heat Sink Model
Obtain a low-order linear parameter-varying (LPV) surrogate for the high-fidelity finite element model of the heat sink.
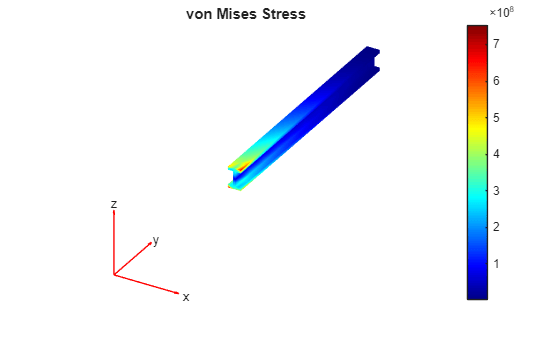
Reduced-Order Modeling Technique for System-Level Simulation of Aircraft Wing Spar
Run system-level simulations by using the Descriptor State-Space block to implement a reduced-order model of the I-beam in an aircraft wing spar.
Ports
Input
Output
Parameters
Block Characteristics
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"simulink/Continuous/Descriptor State-Space"
Example: add_block("simulink/Continuous/Descriptor State-Space","myModel/myBlock",MakeNameUnique="on")
For information about programmatic access to individual block parameters, see the Programmatic Use section of parameter descriptions on this page.

