Decoupled Transform (Six-Phase, Symmetrical)
R2026bDecoupled Transform (Six-Phase, Symmetrical) block
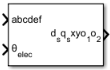
To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Simscape /
Electrical /
Control /
Mathematical Transforms
Description
The Decoupled Transform (Six-Phase, Symmetrical) block converts the time-domain components of a six-phase system in an abcdef reference frame to direct, quadrature, x, y, and zero components in a rotating reference frame.
You can configure the block to align the phase a-axis of the six-phase system to either the d-axis or the q-axis of the rotating reference frame where time t is 0.
Equations
θ = ωt + Offset is the angle between the a and q axes for the q-axis alignment or the angle between the a and d axes for the d-axis alignment, where:
ω is the rotational speed of the rotational reference frame.
t is the time, in s, from the initial alignment.
The Decoupled Transform (Six-Phase, Symmetrical) block implements the transform as
Ports
Input
Output
Parameters
References
[1] Yepes, Alejandro G., et al. "Comparison of Stator Winding Connections in Multiphase Drives under Healthy Operation and with One Open Converter Leg". IET Electric Power Applications, vol. 14, no. 4, Apr. 2020, pp. 584–96. DOI.org (Crossref), https://doi.org/10.1049/iet-epa.2019.0467.
Extended Capabilities
Version History
Introduced in R2026b

