PMSM (Six-Phase, Symmetrical)
R2026bSymmetrical six-phase permanent magnet synchronous motor with sinusoidal flux distribution
Since R2026b
PMSM (Six-Phase, Symmetrical) block
To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Simscape /
Electrical /
Electromechanical /
Permanent Magnet
Description
The PMSM (Six-Phase, Symmetrical) block models a permanent magnet synchronous motor (PMSM) with a six-phase star-wound, hexagon-wound, or hexagram-wound stator. Use this block to model these types of motor, if the motor has six stator windings:
Interior PMSM (IPMSM)
Surface PMSM (SPMSM)
Axial flux (pancake) motor
PMSM servomotor.
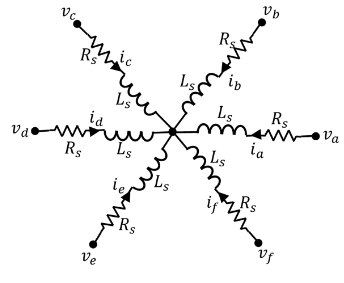
This figure shows the equivalent electrical circuit for the star-connected stator windings.
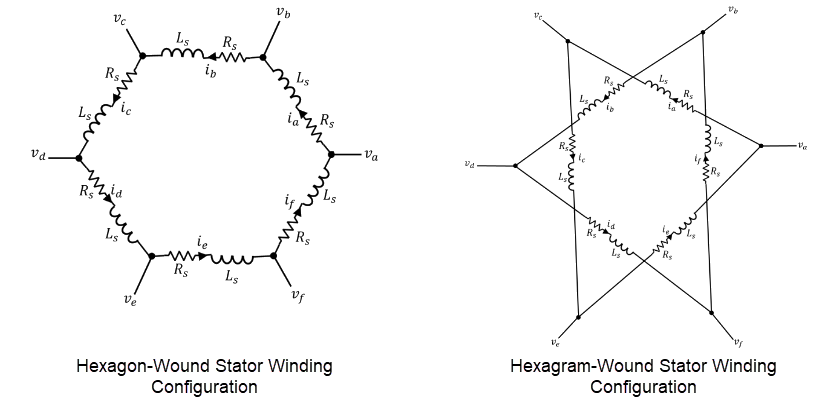
To model the PMSM in a hexagon-wound or a hexagram-wound configuration, set the
Winding type parameter to Hexagon-wound or
Hexagram-wound, respectively.
These figures show the equivalent electrical circuits for the hexagon-wound and hexagram-wound stator windings.
Permanent magnets generate a rotor magnetic field that creates a sinusoidal rate of change of flux based on the rotor angle. For the axes convention:
When you set the Rotor angle definition parameter to
Angle between the a-phase magnetic axis and the d-axis, the a-phase and permanent magnet fluxes align when the rotor mechanical angle θr is zero.When you set the Rotor angle definition parameter to
Angle between the a-phase magnetic axis and the q-axis, the rotor mechanical angle is the angle between the a-phase magnetic axis and the rotor q-axis.
Equations
The voltages across the stator windings are
where:
va, vb, vc, vd, ve, and vf are the individual phase voltages across the stator windings.
Rs is the equivalent resistance of each stator winding.
ia, ib, ic, id, ie, and if are the currents flowing in the stator windings.
, , , , , and are the rates of change for the magnetic flux in each stator winding.
The permanent magnet and the six windings contribute to the total flux linking each winding. The total flux is
where:
ψa, ψb, ψc, ψd, ψe, and ψf are the total fluxes that link each stator winding.
Laa, Lbb, Lcc, Ldd, Lee, and Lff are the self-inductances of the stator windings. These self-inductances are functions of the rotor electrical angle, θe, and depend on the stator per-phase self-inductance, Ls, and the stator inductance fluctuation, Lm.
where θr is the rotor mechanical angle.
rotor offset is
0if you define the rotor electrical angle with respect to the d-axis, or-pi/2if you define the rotor electrical angle with respect to the q-axis.Ls is the stator per-phase self-inductance. This value is the average self-inductance of each of the stator windings.
Lm is the stator inductance fluctuation. This value is the amount that the self-inductance and mutual inductance fluctuate with the changing of the rotor angle.
Lab, Lac, Lba, and so on, are the mutual inductances of the stator windings. These mutual inductances are functions of the rotor electrical angle, θe. They depend on the stator mutual inductance, Ms, and the stator per-phase self-inductance, Ls.
Ms is the stator mutual inductance. This value is the average mutual inductance between the stator windings.
ψam, ψbm, ψcm, ψdm, ψem, and ψfm are the permanent magnet fluxes linking the stator windings.
The permanent magnet flux linking winding a-a' is at maximum when θe = 0° and zero when θe = 90°. Therefore, the linked motor flux is equal to:
where ψm is the permanent magnet flux linkage.
Simplified Electrical Equations
Applying a decoupled transformation to the block electrical equations produces an expression for torque that is independent of the rotor angle.
The decoupled transformation is equal to:
The transformation matrix, P, has this pseudo-orthogonal property:
Using the P transformation on the stator winding voltages and currents transforms them into the dq0 and xy frames, which are independent of the rotor angle. These equations calculate the voltages and currents in the dq0and xy frames
where:
vds, vqs, vx, vy, v01, and v02 are the d-axis, q-axis, x-axis, y-axis, and zero-sequence stator voltages.
ids, iqs, ix, iy, i01, and i02 are the d-axis, q-axis, x-axis, y-axis, and zero-sequence stator currents.
Applying this transformation to the electrical equations produces these equations:
where:
is the stator d-axis inductance.
is the stator q-axis inductance.
is the stator zero-sequence inductance.
ω is the rotor mechanical rotational speed.
N is the number of rotor permanent magnet pole pairs.
T is the torque.
Alternative Flux Linkage Parameterization
You can parameterize the motor by using the back electromotive force (EMF) or torque constants, which are more commonly given on motor datasheets, by using the Permanent magnet flux linkage parameter.
The back EMF constant is the peak voltage induced by the permanent magnet in the per-unit rotational speed of each of the phases. The relationship between the peak permanent magnet flux linkage and the back EMF is:
The back EMF, eph, for one phase is:
The torque constant is the peak torque induced by the per-unit current of each of the phases. It is numerically identical in value to the back EMF constant when both are expressed in SI units:
When Ld = Lq and the currents in all six phases are balanced, the combined torque T is:
where Ipk is the peak current in any of the six windings.
The block obtains the factor 3 from the steady-state sum of the torques from all phases. Therefore, the torque constant kt can also be:
where T is the measured total torque when testing with a balanced three-phase current with a peak line current of Ipk. Using the RMS line voltage, the torque constant kt is:
Model Thermal Effects
You can expose thermal ports to model the effects of losses that convert power to heat. To expose the thermal ports, set the Modeling option parameter to either:
No thermal port— The block contains expanded electrical conserving ports associated with the stator windings, but does not contain thermal ports.Show thermal port— The block contains expanded electrical conserving ports associated with the stator windings and thermal conserving ports for each of the windings and for the rotor.
For more information about using thermal ports in actuator blocks, see Simulating Thermal Effects in Rotational and Translational Actuators.
Variables
To set the priority and initial target values for the block variables before simulation, use the Initial Targets section in the block dialog box or Property Inspector. For more information, see Set Priority and Initial Target for Block Variables.
Nominal values provide a way to specify the expected magnitude of a variable in a model. Using system scaling based on nominal values increases the simulation robustness. You can specify nominal values using different sources, including the Nominal Values section in the block dialog box or Property Inspector. For more information, see System Scaling by Nominal Values.
Ports
Conserving
Parameters
References
[1] Yepes, Alejandro G., et al. "Comparison of Stator Winding Connections in Multiphase Drives under Healthy Operation and with One Open Converter Leg". IET Electric Power Applications, vol. 14, no. 4, Apr. 2020, pp. 584–96. DOI.org (Crossref), https://doi.org/10.1049/iet-epa.2019.0467.
Extended Capabilities
Version History
Introduced in R2026b

